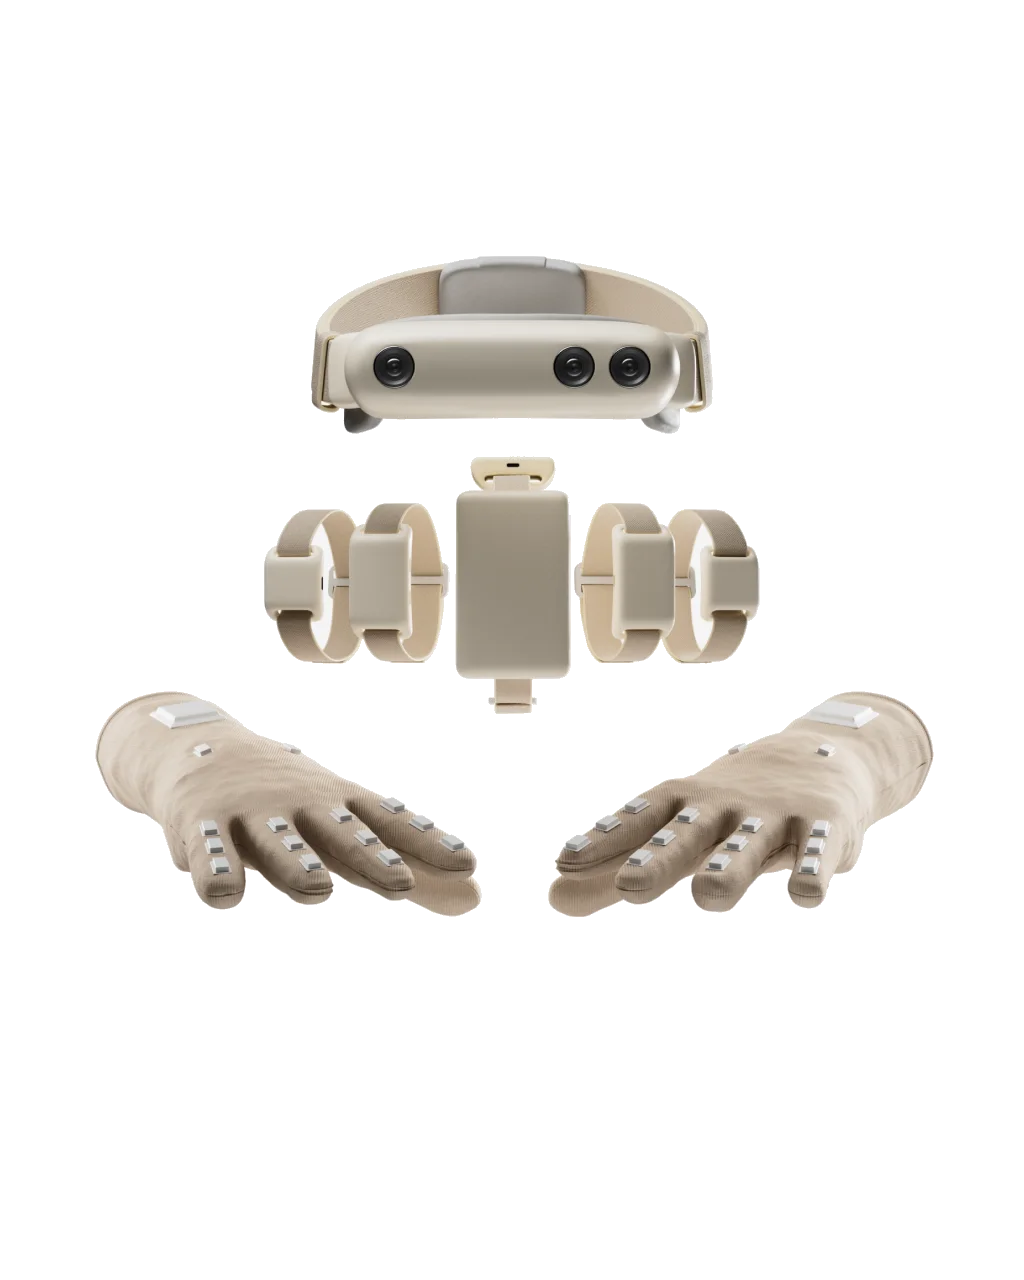
Data Collection Rig
Wear the rig and do the task. No robot is necessary. The rig records from the viewpoint NEO uses, so the data transfers to the robot cleanly.
Full-stack access to the data and the tools we train NEO with. Publish what you build, and use what everyone else publishes.
NEO senses its work in every dimension: vision, depth, force, motion, and sound. The Developer Kit puts that data in your hands.
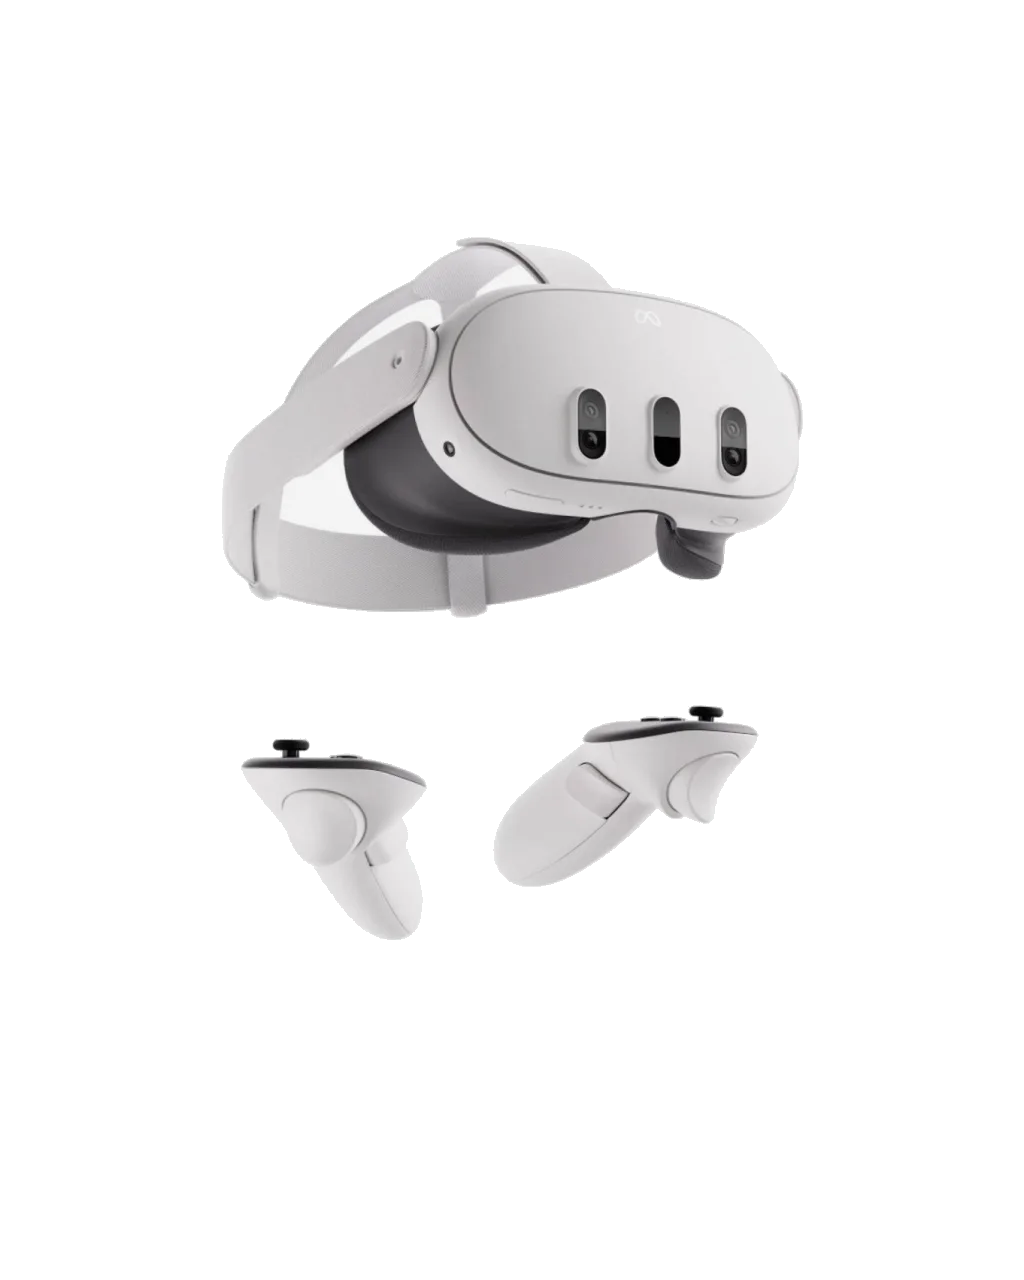
96% Scene Recall
Head
$9,000.00
99% Embodiment
NEO's Body
$20,000.00
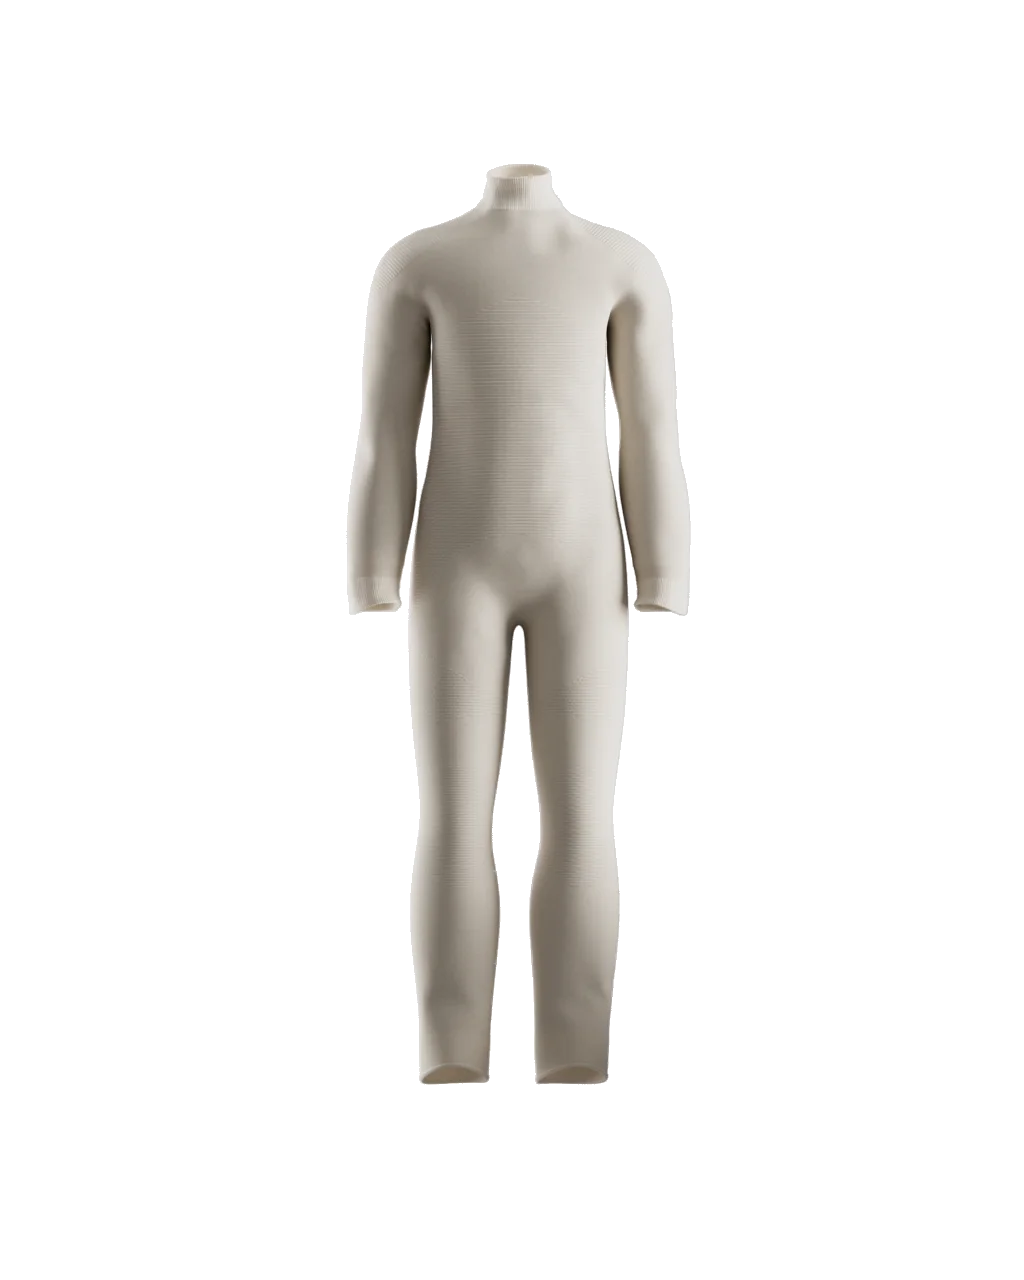
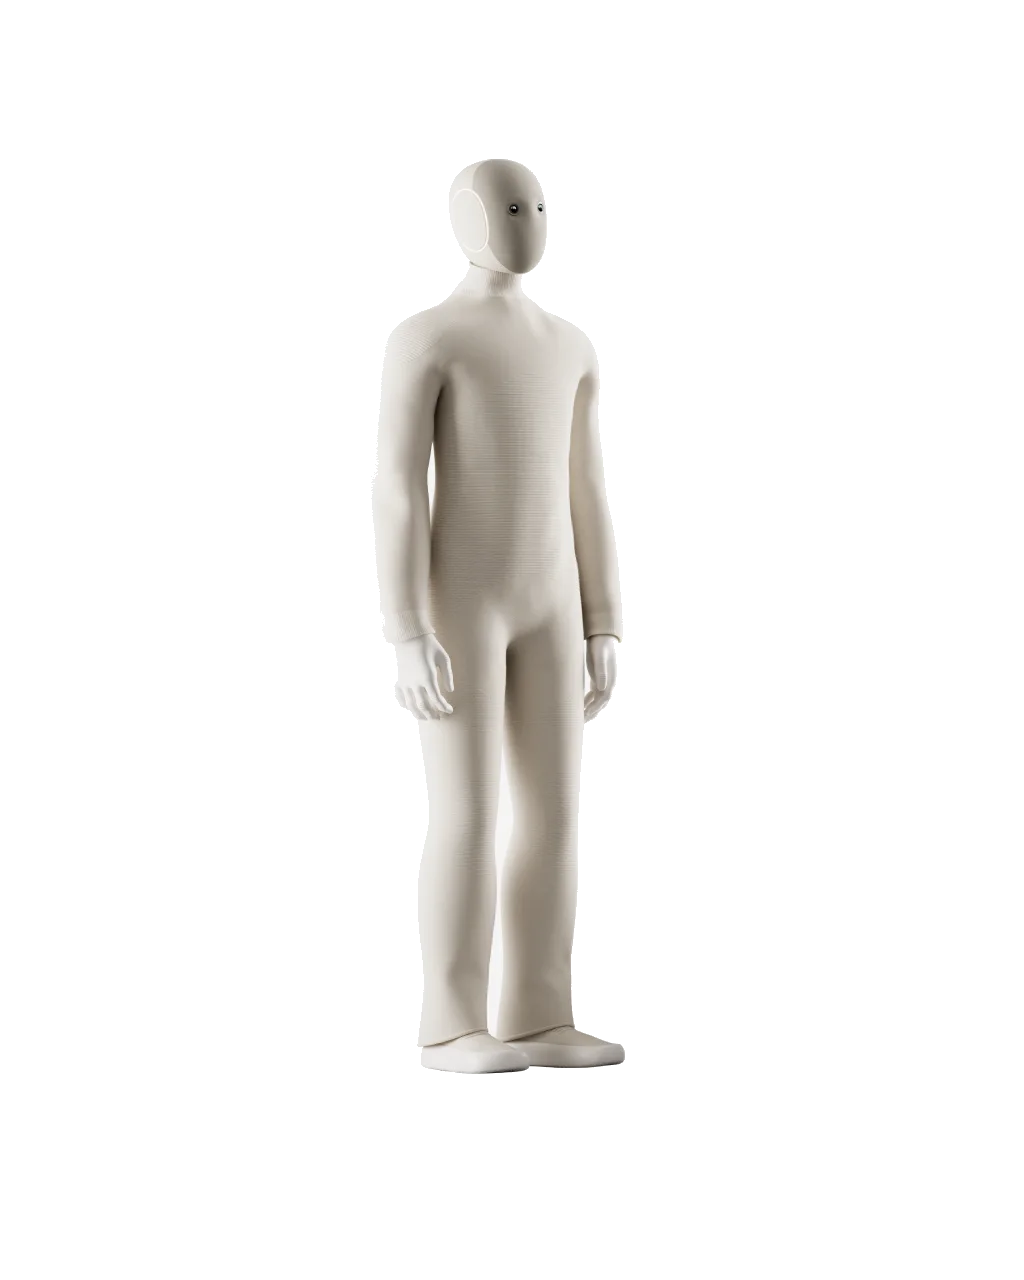
94% Coverage
Suit
$3,500.00
Two ways to record the same data. Wear the rig, or drive the robot. Both write the same schema, through the same hand and the same sensors.
Data Collection Rig
Wear the rig and do the task. No robot is necessary. The rig records from the viewpoint NEO uses, so the data transfers to the robot cleanly.
Tele Operation
Drive NEO through the task yourself. The robot records the same channels while it works.
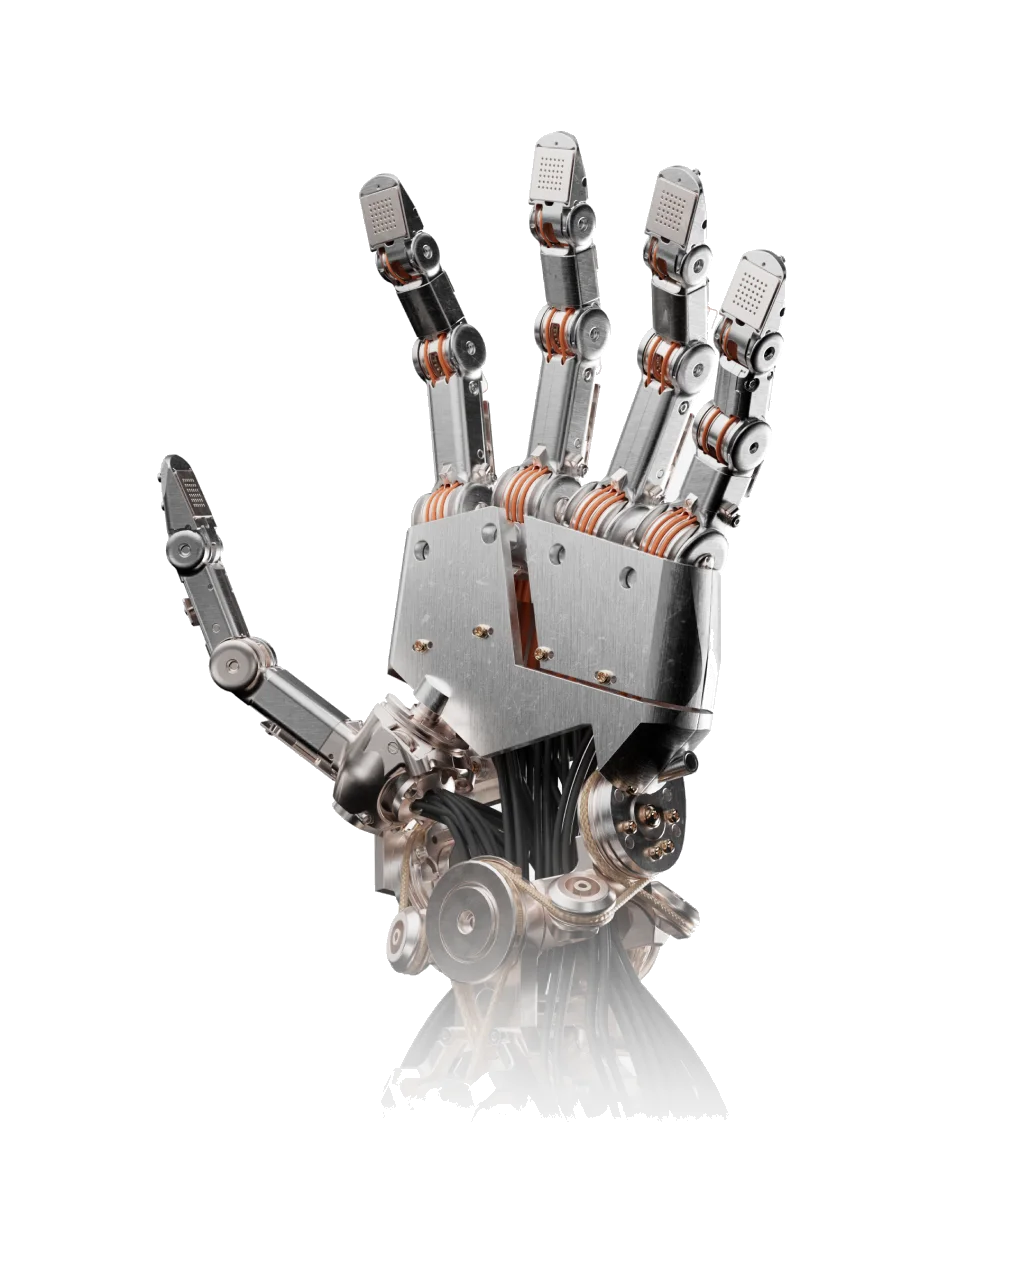
The Best Hand and Sensors
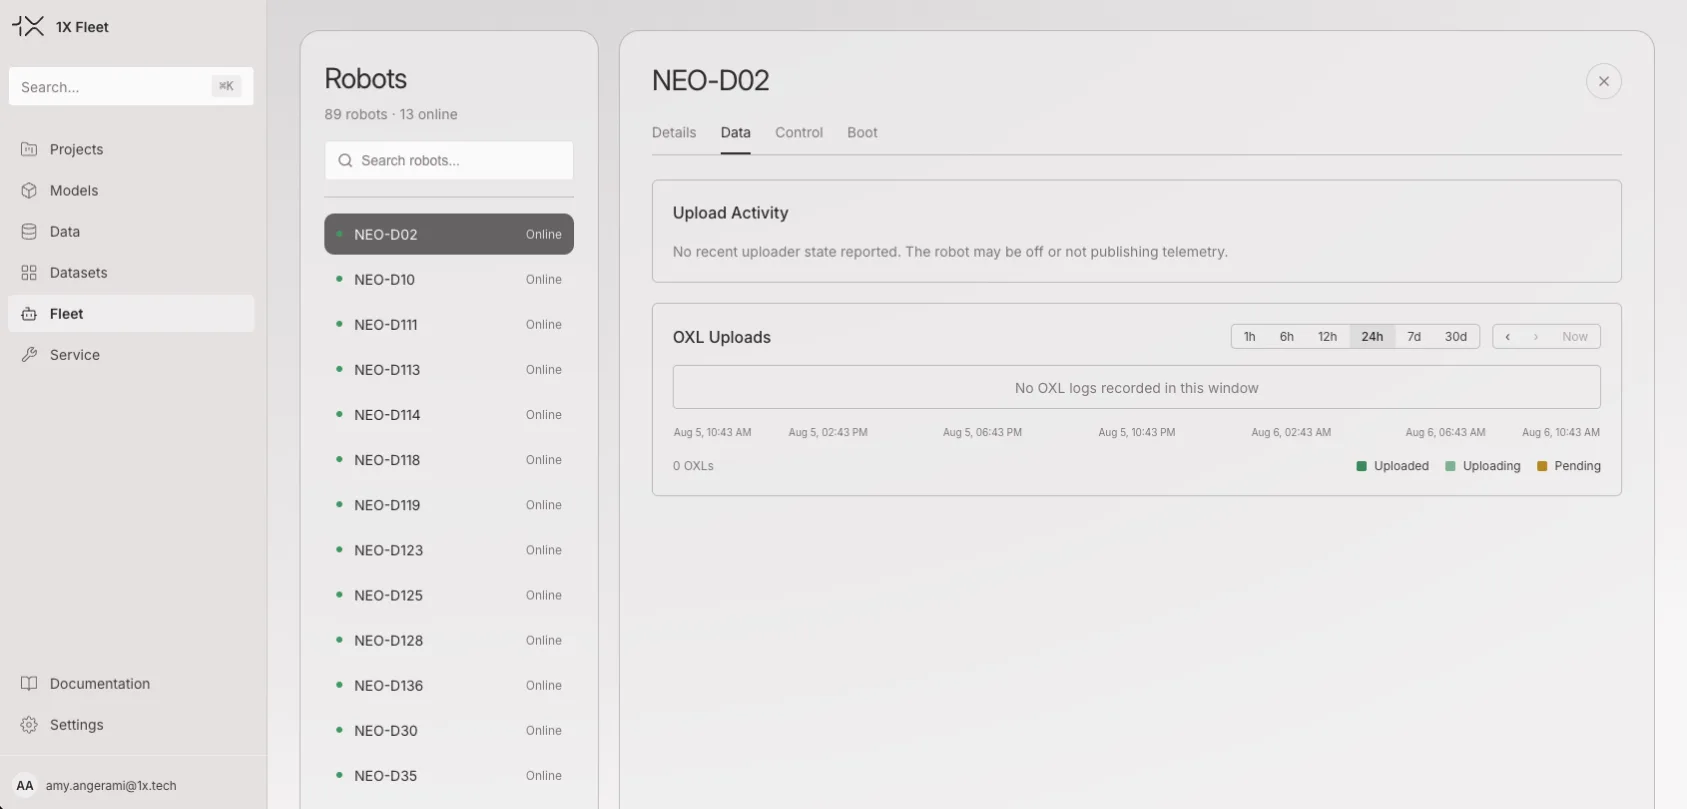
Call the full loop over HTTP. Each endpoint covers one part of the work, from raw data to a policy on the robot.
DATA API
Read and write episode data. Stream sensor records to your own store.
SIM API
Run tasks in simulation. Test a policy before it touches hardware.
Train API
Start training runs. Track progress and pull the checkpoints.
Evaluation API
Score a policy against a task set. Compare runs side by side.
Serve API
Deploy a policy to the robot. Roll back with one call.
Robot API
Send commands to the robot. Read its state and its joints.
Fleet API
Manage many robots together. Group them and push updates.
Calibration API
Calibrate the cameras and the joints. Save the profile to the robot.
Develop in simulation before you own a robot. Build and test your model in NVIDIA Isaac Sim or MuJoCo. Then remote into a 1X facility and run it on a real NEO over a live camera stream. When it works, deploy.
Capabilities
Trusted by industry leaders
Build with the community. Reach a human when you need one. Keep control of your data.
Community
Build models with other developers. Publish your trained policies and import open models from Hugging Face.
Technical Support
Message the 1X team direct. We repair and service your robot in person.
Govern Your Data
Your data stays yours. Develop in private and publish when you are ready. You set the terms: public, private, or licensed.
Every published number on NEO: body, actuation, sensing, and compute. The developer kit runs the same hardware.
Whole body controller
On-board
Runs without the cloud. Runtime access for approved users.
1X NEO Cortex
Nvidia Jetson Thor
2070 FP4 TFLOPS peak. Deploy your own binary to it.
Full connectivity
Wi-Fi 6E · 5G · Ethernet
Direct, low-latency teleoperation link.
Robot
Degrees of Freedom
Speed
Battery
Safety
Ingress Protection
Tendon Drive
Compute
Source, binaries, logs, and the control layer.
The same monorepo
The repo our engineers build from. Same build system, same targets, same deploy path.
Deploy to the Jetson Thor
Ship your binary to NEO's on-board compute. Not a cloud endpoint.
Controller runtimeApproved users
Write to the whole-body control layer.
Every capnp definition
The log schema ships in the SDK. Parse the logs, build your own infrastructure on them.
Redirect log egress
Point any stream at your bucket. Your keys, your storage.
Private by default
We host your logs. You view and download them. Nobody else reads them.
Opt in, never opt out
Data sharing is a program you join. Not a default you leave.
The same kit and the same full-stack access for everyone. What changes is what we take off the price, and we take it off whatever is actually in your way.
Individual
For developers buying their own kit.
Every part at list price.
Education
For universities and research labs.
25% off every part.
Enterprise
For robotics teams shipping in production.
Every part at list price, every service free.